Atlas Drops the Pinky—On Purpose
Boston Dynamics' new four-fingered hand trades anatomical fidelity for sim-ready reliability and tool-grade grip.
By The Robotics Desk
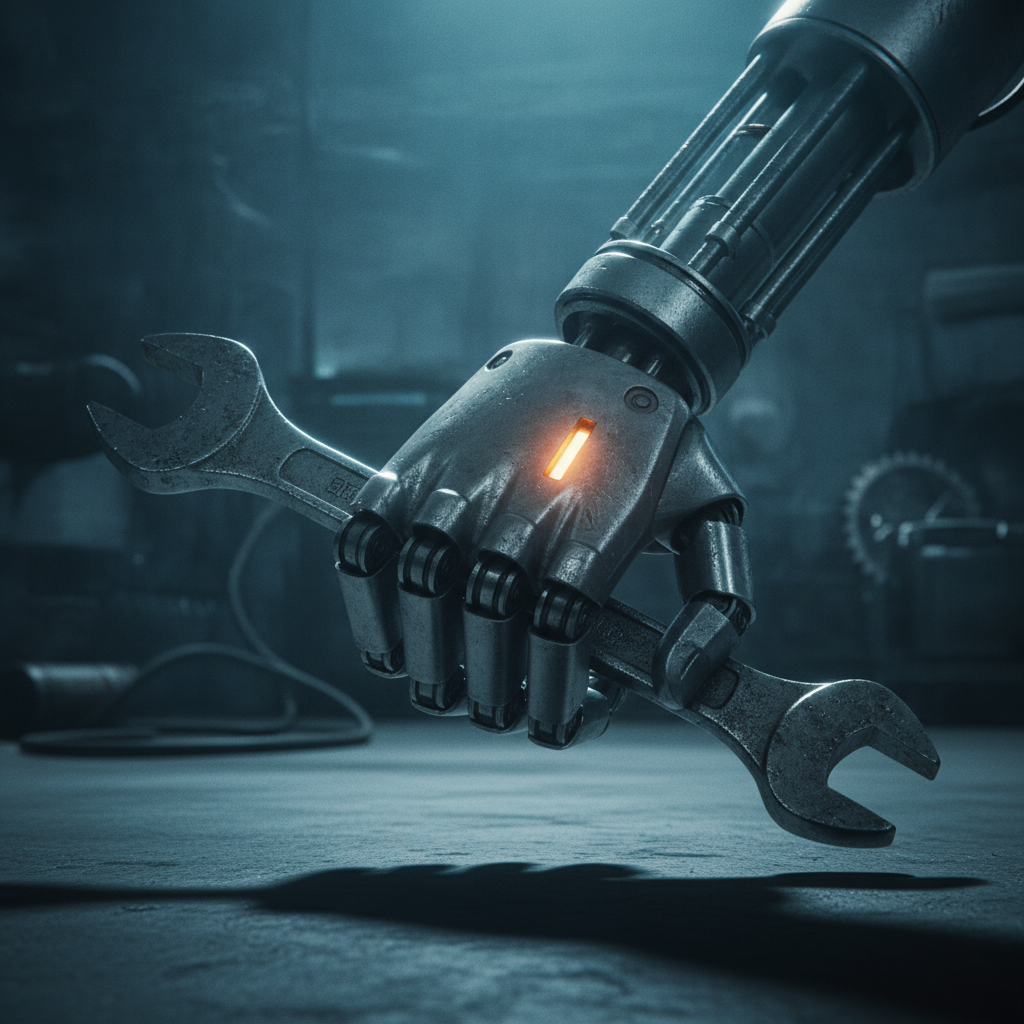
Boston Dynamics has unveiled a new hand for its Atlas humanoid: four fingers, 13 degrees of freedom, directly actuated, and built for mass manufacturing—with no pinky in sight. [1]
[1] The new design shifts the mandate toward manipulation—drills, power torque drivers, grinders, nail guns, welding torches. [1] Before the design was finished, Zachary Jackowski, Boston Dynamics' chief product and technology officer, asked the team to tape their pinky and ring finger together for a day and report back on what they weren't able to do. [1] At the end of the experiment, the team had agreed the robot hand didn't need a pinky.
[1] The hand is sized close to a large human hand—a deliberate choice that shrinks the cross-embodiment gap when learning from human manipulation data. [1] Dense pressure tactile sensors cover the fingertips and palm, complementing proprioception for fine contact signals. [1]
The deeper design driver is simulation. [1] That fidelity lets RL train robust control policies with exposure to randomizations of motor torque profiles, surface friction coefficients, object geometries, and task disturbances before a single physical trial. [1] The company reports promising sim2real transfer in dynamic tasks. [1]
The choice to subtract—rather than add—reflects a broader tension in humanoid design: anatomical completeness versus operational clarity. Less hand, sharper purpose.
Atlas is already being deployed toward Hyundai's automotive manufacturing operations: Boston Dynamics recently opened its Robotics Metaplant Application Center (RMAC) at Hyundai Motor Group Metaplant America in Georgia, a training center for integrating Atlas humanoids into those operations. [1] The new hand is the next thing it will bring to the line.